Solution Methods and Solver Settings
The openTEPES model can be solved using different solution methods, depending on the size of the problem and the available computational resources. The solution method comprises the decomposition of the problem and the solver settings.
Solution methods
Complete problem
The optimization problem can be solved directly using a commercial solver (e.g., Gurobi, CPLEX) or an open-source solver (e.g., HiGHS, CBC, GLPK). This method is suitable for small to medium-sized problems. As a rule of thumb, a linear optimization problem requires 1 GB of memory for every 1 million rows. For a mixed-integer linear optimization problem, the requirements are much higher, and they depend on the number of binary variables and the number of constraints that include them.
Stage Benders decomposition
See also some Benders decomposition publications applied to TEP:
S. Lumbreras, A. Ramos “How to Solve the Transmission Expansion Planning (TEP) Problem Faster: Acceleration Techniques Applied to Benders Decomposition” IET Generation, Transmission & Distribution 10: 2351-2359, Jul 2016 10.1049/iet-gtd.2015.1075
S. Lumbreras, A. Ramos “Transmission Expansion Planning using an Efficient Version of Benders’ Decomposition. A Case Study” IEEE PowerTech. Grenoble, France. June 2013 10.1109/PTC.2013.6652091
It solves the complete model, decomposed by the stage Benders decomposition method (file openTEPES_ProblemSolvingStageDecomposition). The master problem
determines the investment decisions and the subproblem the operation decisions. The subproblem is solved by stages (e.g., weeks or months). The definition of
a stage is done in the file oT_Data_Duration by assigning each time step to a stage. The duration of the
stage (weekly —168 h—, monthly —672 h—, quarterly —2184 h—, or semester —4368 h—) is chosen based on what makes sense from a system operation point of view.
This value must be larger than or equal to the shortest duration of any storage type (e.g., weekly).
Inventory levels of ESS at the end of every stage are fixed for the decomposition, i.e., consecutive stages are not tied to each other.
Only DC candidate lines are allowed, in order to keep convexity in the subproblem with respect to this investment decision variable.
There are three possibilities for solving the decomposed problem (file openTEPES_ProblemSolvingStageSolve):
In parallel: writes the LP file for the solver and sends the problems to a queue. It only works with the serial solver manager factory.
Sequentially (LP file): writes the LP file for the solver and solves each stage sequentially.
Sequentially (in memory): loads the problem in memory and solves each stage sequentially. It takes a long time to load the problem in memory.
Sector Benders decomposition
It solves the electric sector and the hydrogen sector separately, using the Benders decomposition method (file openTEPES_ProblemSolvingSectorDecomposition).
Solver settings
Solver interface: persistent vs non-persistent
The solver name (the SolverName argument of openTEPES_run, or the solver entered at the openTEPES_Main prompt) also selects the interface between Pyomo
and the solver.
Non-persistent interface (default). gurobi, cplex, highs, gams, glpk. Pyomo exports the complete model at every solve to a new
solver object (SolverFactory(SolverName)). This interface is available for every solver; the default solver is highs. The solver connection is done
by an LP file written to disk and the problem is not kept in memory. For gurobi_direct the solver connection is done by writing the problem in memory, but
the problem is not kept in memory.
Persistent interface. appsi_gurobi, appsi_cplex, appsi_highs, (APPSI, pyomo.contrib.appsi) or gurobi_persistent, cplex_persistent
(the earlier interface). The solver instance is attached to the model once (set_instance); later solves transfer only the modifications: variable bounds and,
for appsi_gurobi, parameters and constraints.
Gurobi can restart from the previous basis when the same instance is re-solved with small changes, as in the sector Benders decomposition. Between stages the
constraints change, and the gain comes from avoiding the export of the model, not from the basis.
For these, the solver connection is done by writing the problem in memory, and it is also kept in memory. APPSI interface provides a more efficient way
to interact with the solver and is recommended.
Relevance for large cases. A case involves many solves: one per (period, scenario, stage), an LP re-solve with the integer and investment decisions fixed
to obtain the dual variables (LMPs), and the iterations of the Benders decompositions. For a large model solved with Gurobi, the persistent interface avoids the
export of the model at each solve; the plain gurobi name forgoes this gain. A single-stage LP, or any HiGHS solve, gains little from it.
Non-persistent interface in Mode C. The hot-swap re-solve (resolve, see Multiple runs) exports the model with the current values of the mutable
parameters at every solve; hence, it requires a non-persistent solver name.
Examples:
from openTEPES.openTEPES import openTEPES_run

# default: HiGHS, non-persistent
openTEPES_run("cases", "9n", "highs", 1, 0)

# persistent Gurobi (APPSI): one solver instance reused across the stage loop and the dual re-solve
openTEPES_run("cases", "9n", "appsi_gurobi", 1, 0)

# older persistent Gurobi interface
openTEPES_run("cases", "9n", "gurobi_persistent", 1, 0)
LP algorithm
The LP algorithm is selected by openTEPES (file openTEPES_ProblemSolvingTuning.py), as shown in the figure; green boxes denote the barrier method.
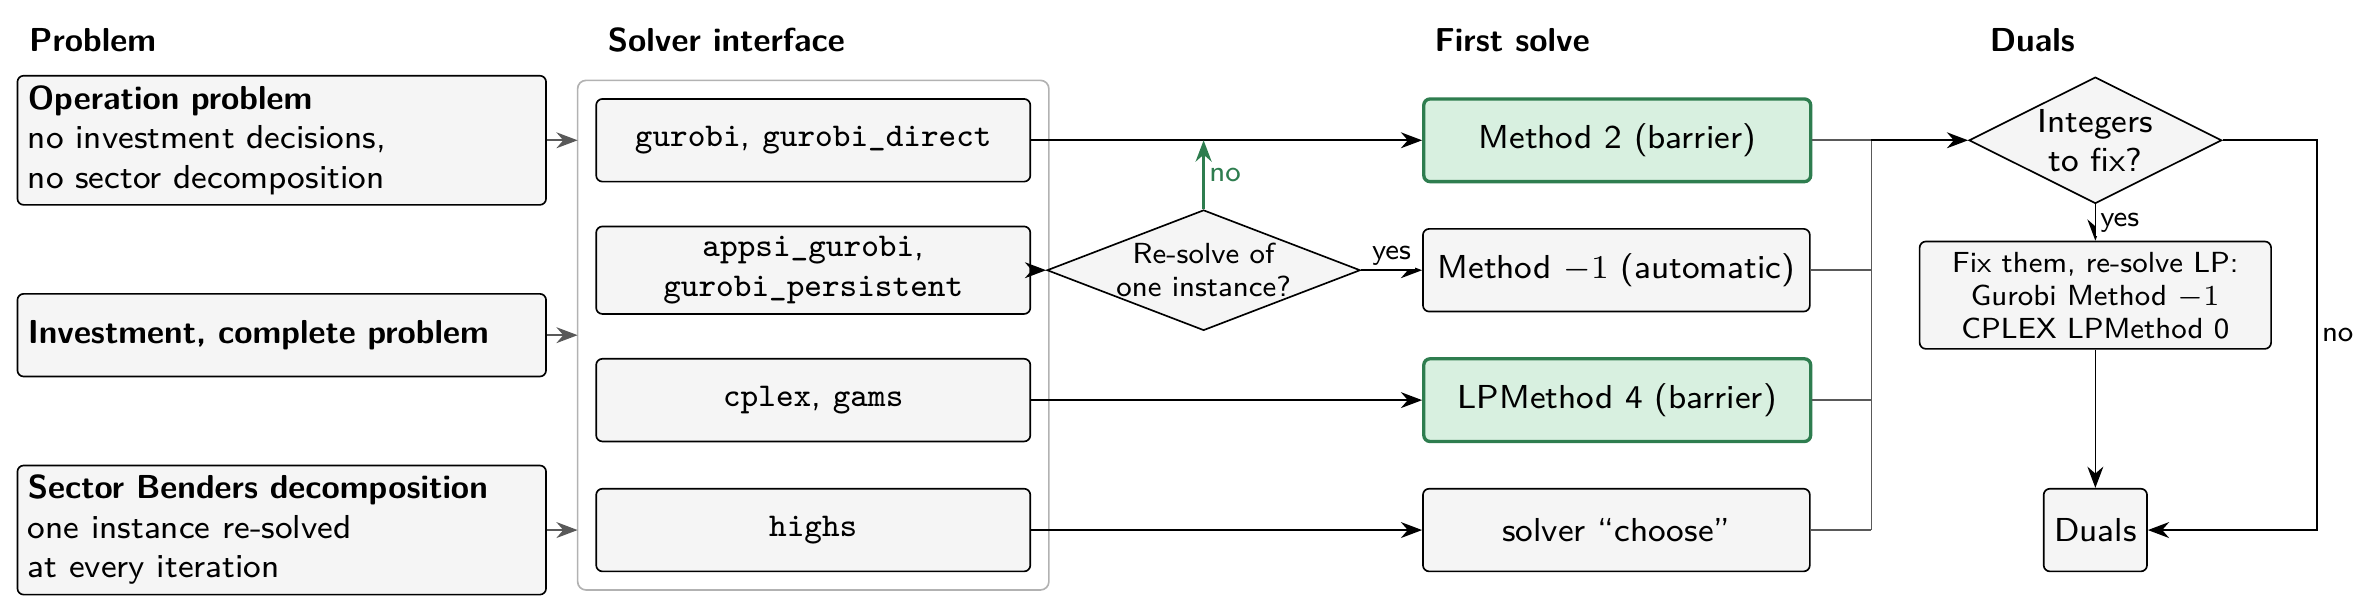
gurobi,gurobi_direct,cplexandgams: barrier method for every problem (Method=2for Gurobi,LPMethod=4for CPLEX).appsi_gurobiandgurobi_persistent: barrier method for the first solve of an instance, and automatic method (Method=-1) for the latter solves of the same instance, i.e., the later periods and scenarios of an operation problem and the iterations of the sector Benders decomposition.highsand the remaining solvers: default settings of the solver.After a mixed-integer (MIP) solve, the LP with the integer and investment variables fixed is re-solved with the automatic method to obtain the dual variables (
Method=-1for Gurobi,LPMethod=0for CPLEX).
The barrier method yields the same dual variables at every solve of the same problem. The automatic method of Gurobi runs the barrier and simplex methods concurrently and returns the first solution; on a degenerate LP, whose duals are not unique, the duals may therefore change from one solve to the next.
The option --crossover 0 omits the crossover after a Gurobi barrier solve, which reduces the solution time; at degenerate points, some duals then differ from
those of a basic solution.